Related Topics:
-
-
-
High Temperature Resistance of American Wavelength Division Multiplexing
Here, we develop a novel design approach that co-optimizes inverse-designed wavelength division multiplexers and distributed Bragg gratings to achieve ultra-low crosstalk without compromising insertion loss. Current solutions are limited by trade-offs between channel spacing, crosstalk, insertion. In fiber-optic communications, wavelength-division multiplexing (WDM) is a technology which multiplexes a number of optical carrier signals onto a single optical fiber by using different wavelengths (i. This technique enables bidirectional communications over a. Corning DWDM multiplexers and demultiplexers utilize advanced thin-film filter and athermal waveguide technology designed for low insertion loss, high isolation, and excellent temperature stability in a totally passive device. They are available in various channel counts at ITU industry standard. Flexible and compact optical switch is important for optical communications. We further demonstrate 2-channel operation for 20Gbps aggregate data rate. -
-
What are the models of galvanized cable trays in El Salvador
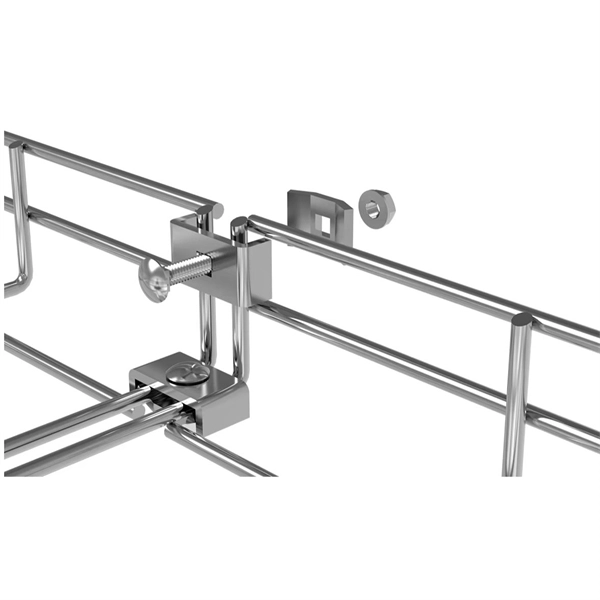
Learn how to select the right galvanized cable trays for industrial environments, ensuring long-term corrosion resistance. What are Galvanized Cable Trays? They are a type of cable support system. As one of the best Galvanized Cable Tray Manufacturers in El Salvador, we are trusted by people not only within the boundaries but even beyond that. Our custom-based products are able to match up your distinct needs. Ordinarily, the coating thickness ranges between 12 and 20microns (Z120-Z275). They are ideal in office buildings or factories that are clean. The full-shaped HDG trays are dipped into a large. There are several types of cable trays, including ladder, perforated, solid bottom, basket, and channel trays. Each cable tray type performs a different function and comes in various materials such as aluminum, galvanized steel, and FRP. -
-
-
Can a fiber optic junction box be used to connect broadband
These boxes are widely used to connect optical fibers and can handle large amounts of fiber optic cables at lower cost and higher flexibility. A Fiber Terminal Box (FTB) is a customer-side termination and distribution device used at the end of the optical network. In this article, we will delve into the world of fiber optic distribution boxes - what they are, their importance, types, installation process, advantages, common challenges, maintenance practices, and future. Think of a Fiber Terminal Box (also known as a Fiber Optic Terminal Box or Optical Distribution Box) as the dedicated hub for managing and distributing fiber optic signals, primarily in the "last mile" or within premises. -
AP Optical Flow Module
Optical Flow uses a downward facing camera and a downward facing distance sensor for velocity estimation. It can be used to determine speed when navigating without GNSS — in buildings, underground, or in any other GNSS-denied environment. The video below shows PX4 holding position using the Ark. CAN (4P GH1. 25mm with DroneCAN protocol) DroneCAN Optical Flow | Vimdrones Can Flow | Ardupilot | PX4 | AP_Periph 1. 6 | PMW3901 | VL53L1X | Open Source Dronecan Optical Flow and Distance Sensor Module Specification Type Value Power supply 5V Support Flight Controller Firmware Ardupilot | PX4. If the vehicle has a GPS, the inflight calibration procedures is the easiest way to get a good calibration: An alternative method which avoids the need to land and change EKF3 parameters between calibration and testing is to setup GPS/Non-GPS transitions so the pilot can manually change between GPS. ArduPlane, ArduCopter, ArduRover, ArduSub source. I want to say that the ArkFlow is working amazingly, way better than the PX4Flow we had previously. – Alin Grig Have used them and they're top notch! – Ryan Johnston Building a DIY indoor optical flow drone can be difficult if you don't know where to start, but there's good news! In this post, I will break down every single step required to build your own optical flow drone.